Project Overview
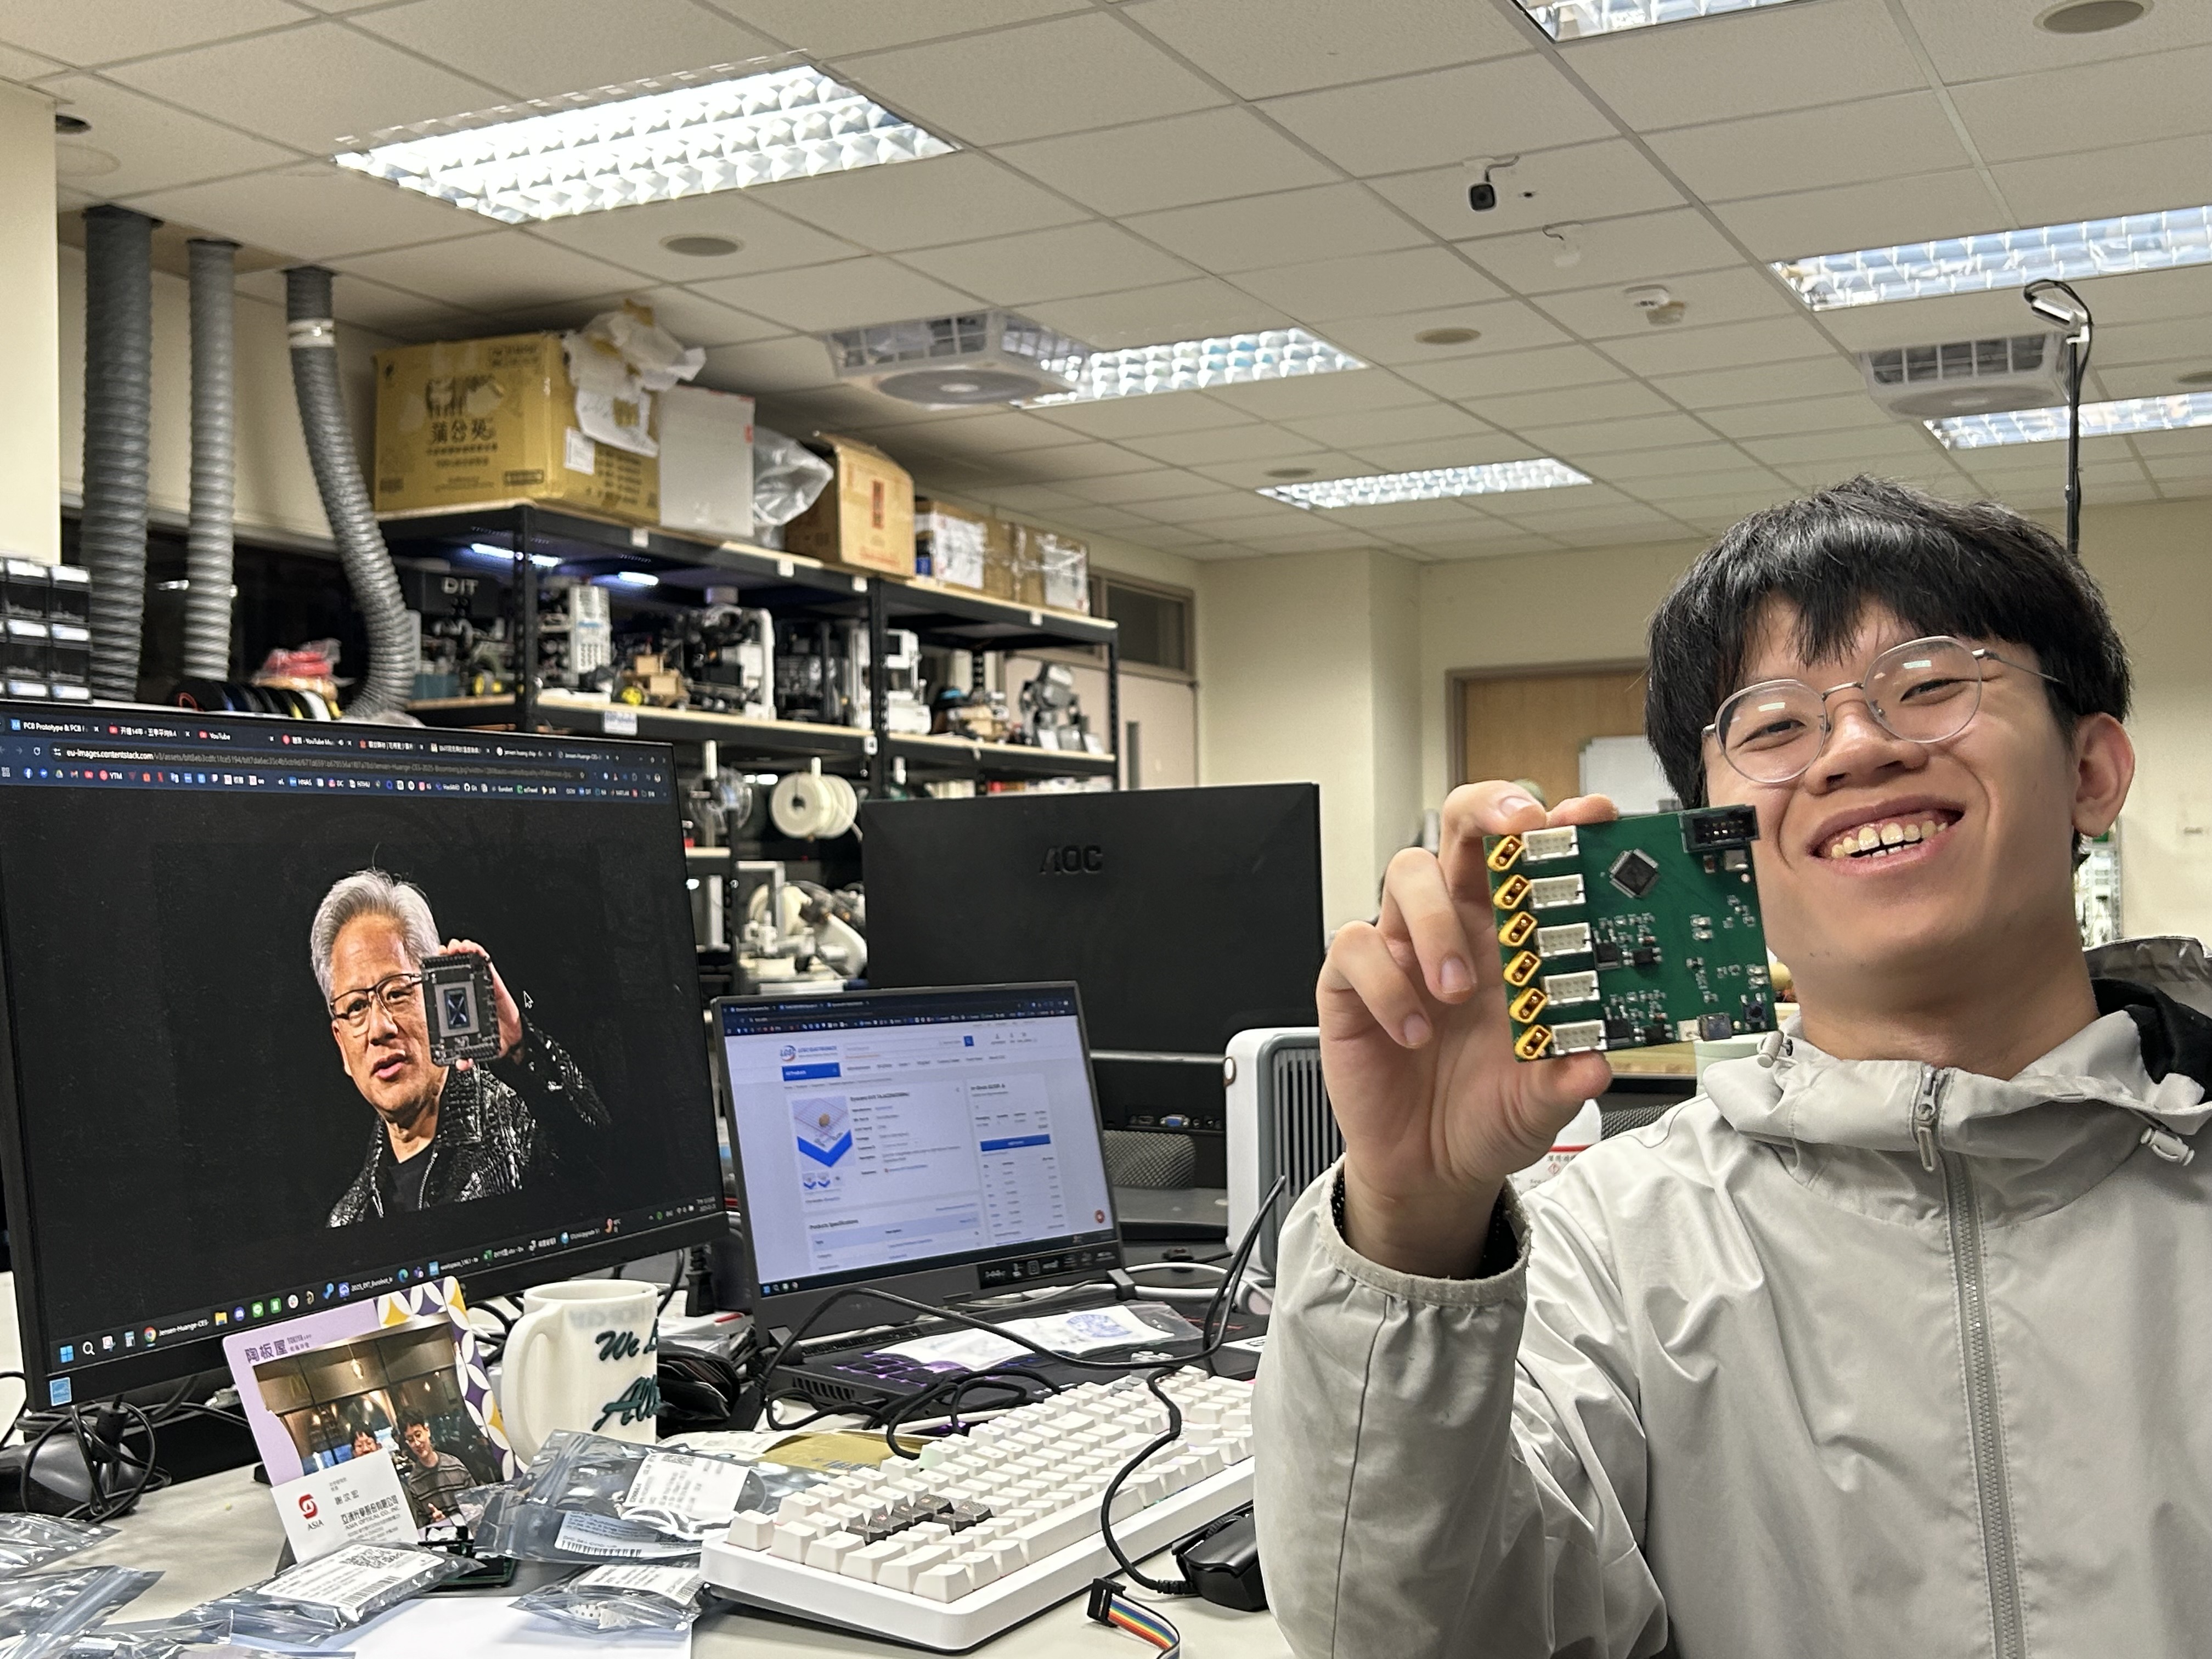
This is a custom-designed mission control board engineered for competitive robotics (Eurobot), working in harmony with our self-made XL4015 buck converter array.
Commercial development boards (such as the STM32 NUCLEO-F446RE) are bulky and laden with unneeded components, making them ill-suited for strict dimensional constraints. To optimize space utilization and eliminate wiring fragility, I developed this compact 80mm x 86mm mission controller.
Technical Specifications
- Microcontroller: STM32F446RE (180MHz ARM Cortex-M4, 512KB Flash, 128KB SRAM)
- Dimensions: 80mm x 86mm
- Servo Outputs: 18 individual PWM servo channels
- High-Power Actuator Control: 4x MOSFET channels (LR7843 with PC817 optocoupler isolation)
- Pressure Sensor Ports: 3x MPXV7007DP differential pressure sensors
- Distance Sensor Ports: 2x VL53 ToF distance sensors
- PCB Architecture: 4-layer stackup with all components mounted on the top side for cost-effective single-sided PCBA manufacturing
- Programming Interface: ST-Link V2 header
Schematic & 4-Layer High-Density Layout
All critical routing—including high-speed crystal oscillator traces, analog pressure lines, and heavy-current switching circuits—was routed manually to guarantee noise immunity.
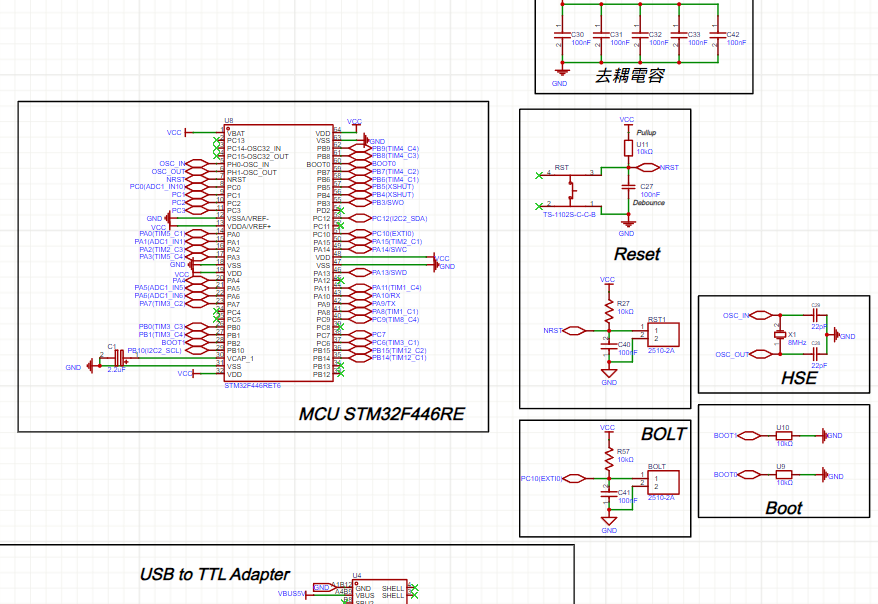
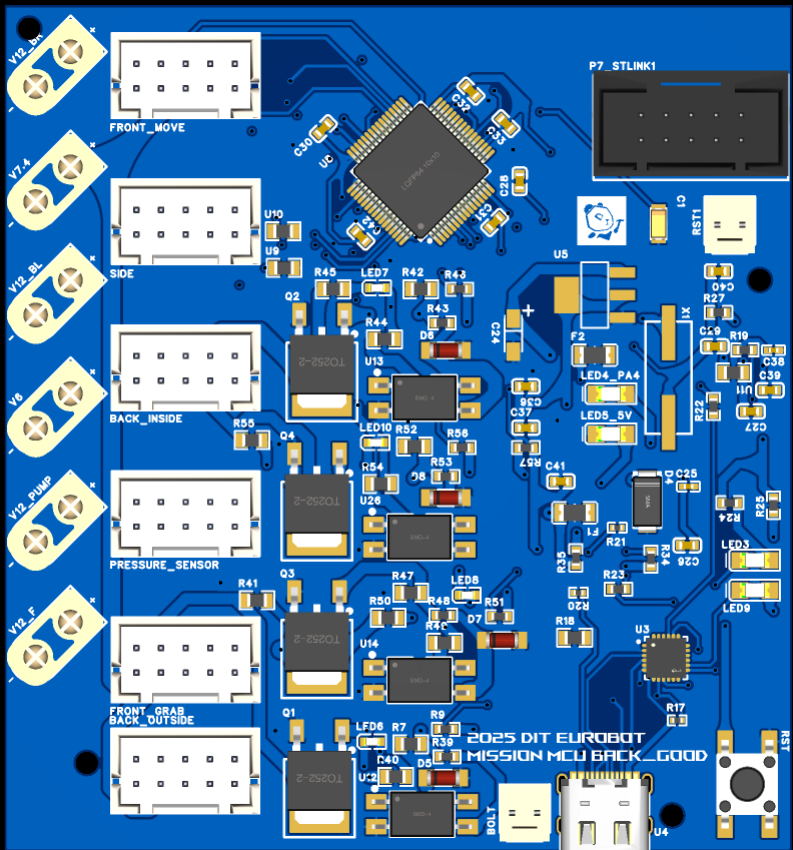
Click on any image above to open the full-screen PhotoSwipe lightbox for high-resolution inspection.
Fabrication & Prototyping
Final production units were manufactured by JLCPCB PCBA, while initial verification prototypes were hand-assembled via hot-plate reflow soldering to validate circuit operation and footprint clearances.
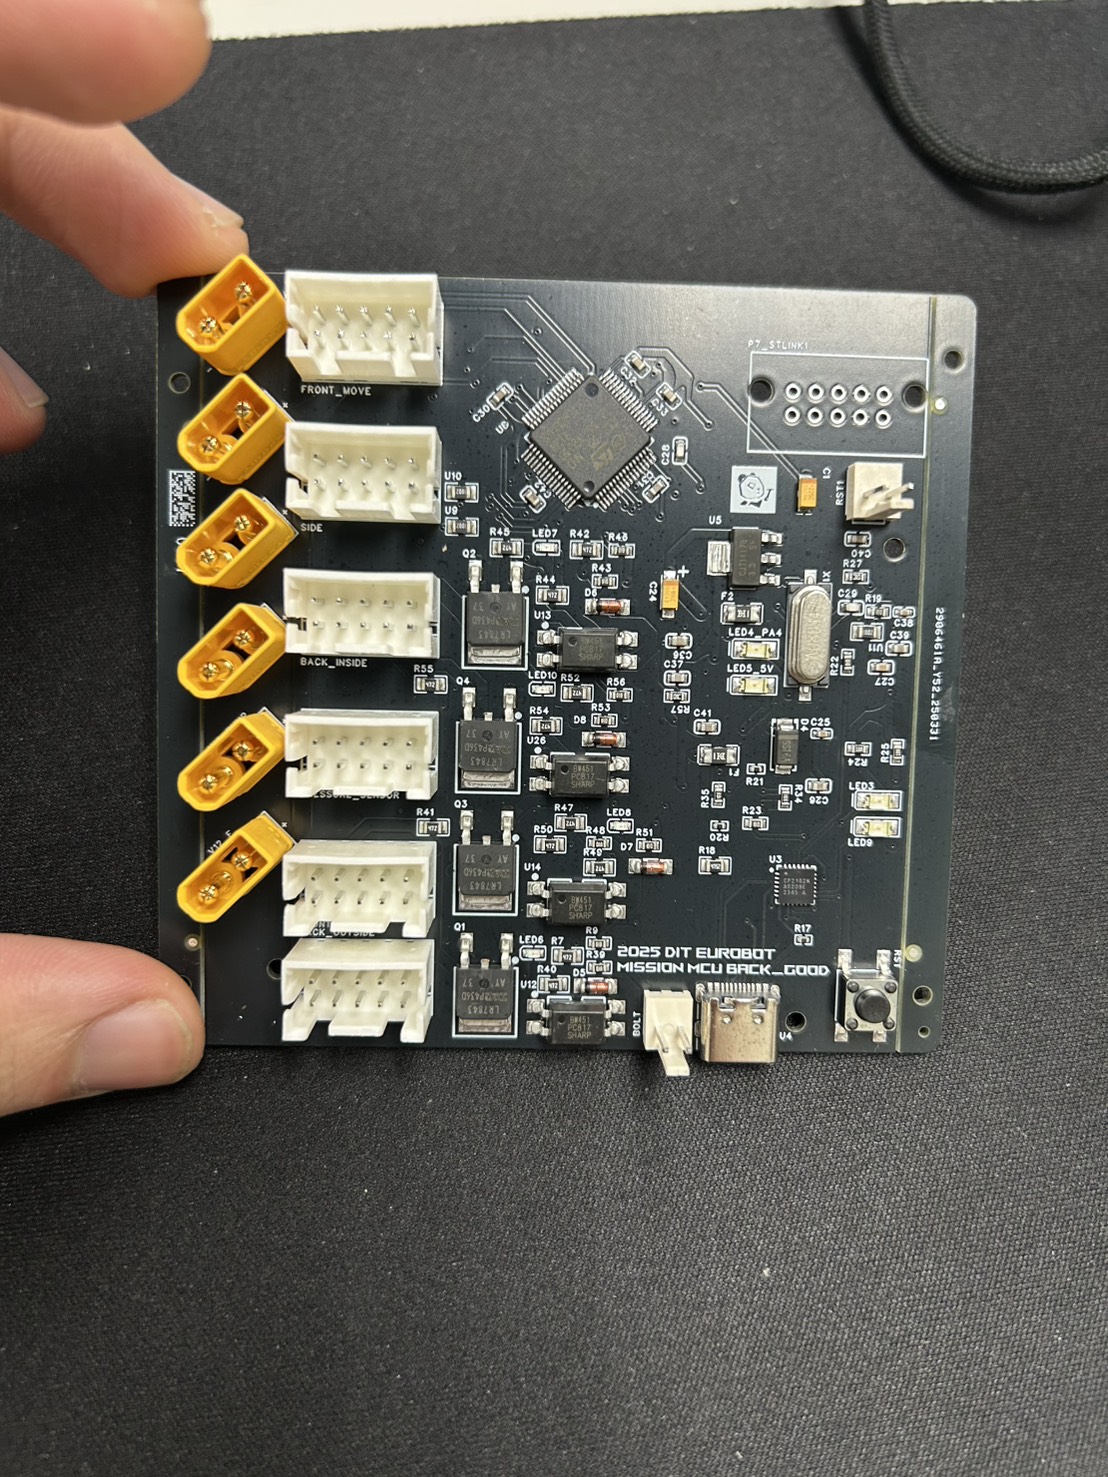
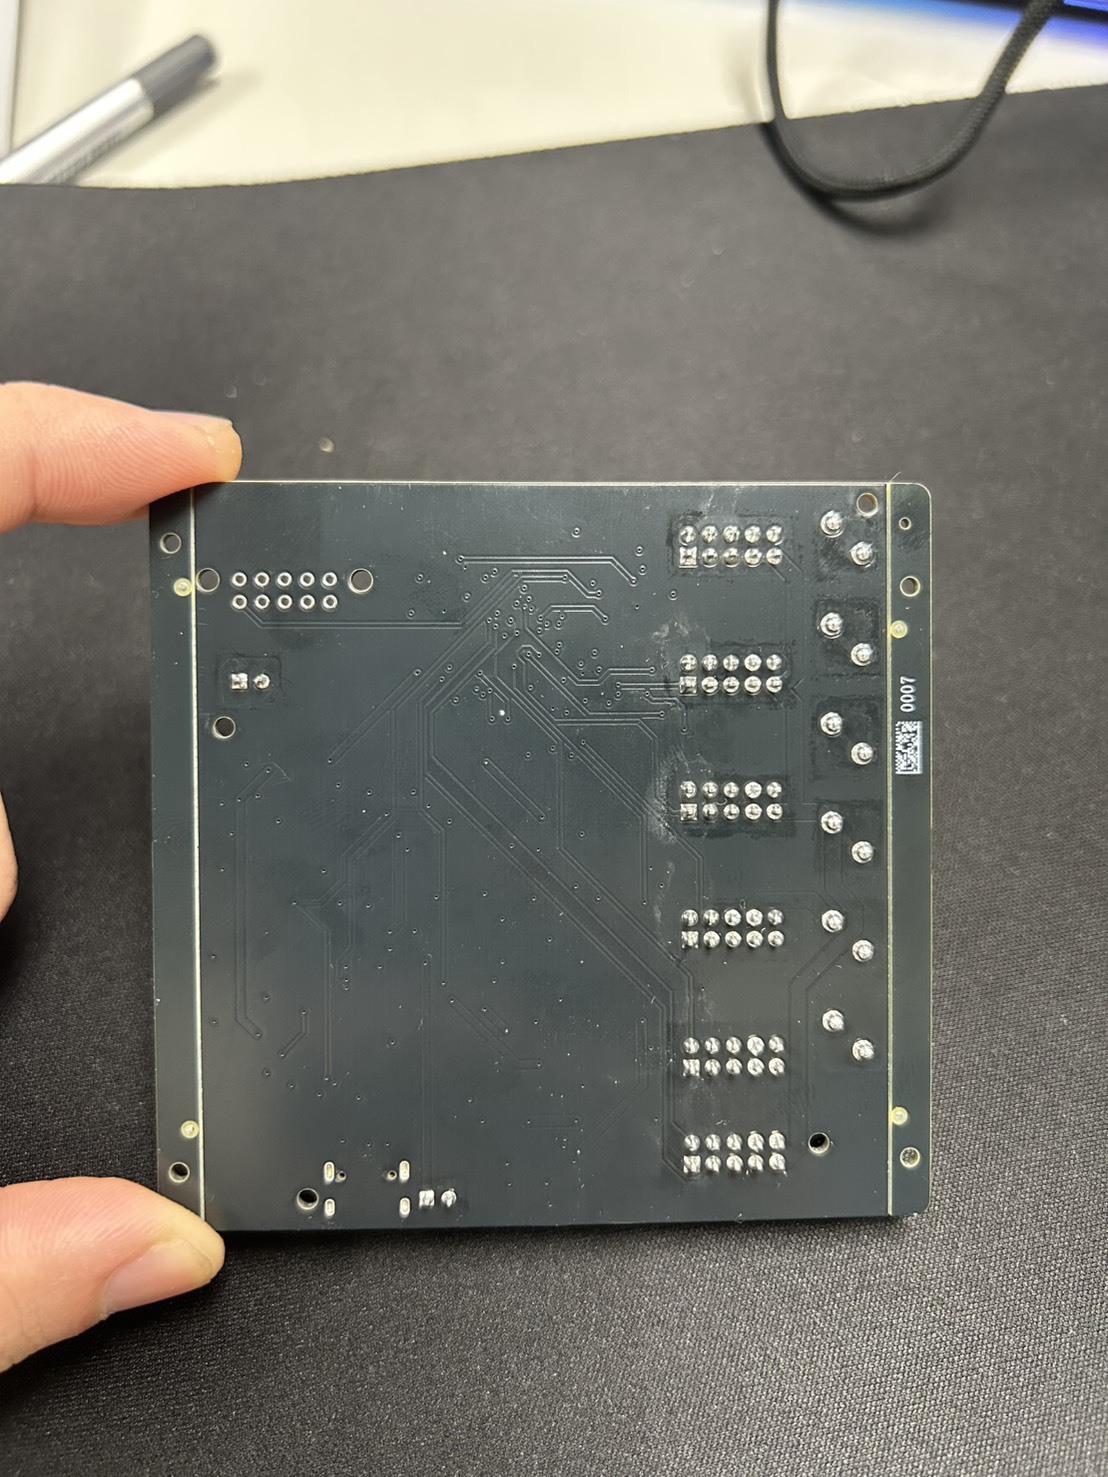
Key Advantages & Impact
- Form Factor Reduction: Shrinks volume by over 60% compared to off-the-shelf NUCLEO boards stacked with expansion shields.
- Rock-Solid Reliability: Automated SMT assembly combined with optocoupled noise isolation prevented actuator EMI interference throughout the competition season.
- Direct Modular Interfacing: On-board custom terminals connect directly to robot actuators, eliminating messy loose wiring.
Open Source Repository
The complete schematic and PCB layout design files (EasyEDA Pro) are open source:
- OSHWLab Repository: 2025_dit_eurobot_mission_-mcu_board Project Link